Computer Vision & AI Software Engineer

Gayan
Brahmanage

Ph.D. · M.Sc. · B.Sc.

SLAM · 3D Perception · Deep Learning · Estimation · Robotics

About

Gayan is a computer vision and deep learning software engineer with 8+ years of ML-based real-time software development experience, and holds a Ph.D. and M.Sc. in Electrical & Software Engineering from the University of Calgary. His work is grounded in Bayesian estimation, SLAM and 3D perception, with a track record of designing and optimizing AI-driven vision systems for intelligent video analytics — spanning classification, object detection, depth prediction and full 3D reconstruction.

He works fluently in C++ and Python to build real-time, scalable solutions for complex computational problems, with particular depth in custom CUDA-accelerated development and GPU-based recursive probabilistic estimators. Outside contract work, he has designed and led robotics projects — including an interactive receptionist robot for the City of Calgary — and shares much of his research on GitHub and YouTube.

Education

  1. 2018 – 2024

    Ph.D., Electrical & Software Engineering

    Schulich School of Engineering, University of Calgary

    Estimation theory, SLAM, deep learning and AI-generated 3D.

  2. 2015 – 2017

    M.Sc., Electrical & Computer Engineering

    Schulich School of Engineering, University of Calgary

    Grade: 6A+. Thesis: RGB-D SLAM for Autonomous Robots.

  3. 2008 – 2013

    B.Sc. (Hons) Engineering — Robotics

    University of Moratuwa, Sri Lanka

    Second Class Upper Division.

Experience

2018 – 2025

Computer Vision Software Engineer

Complex System Inc., Calgary, AB, Canada · Mar 2018 – Sep 2025

Leads video analytics projects end to end — research, real-time implementation and deployment — optimized for hardware constraints, performance and reliability.

  • 3D obstacle detection for the Canadarm2, Canadian Space Agency (2024) — led a team of four engineers building a system to detect and estimate the 3D position of foreign objects within an 8×8×8 m volume using a single monocular camera on the ISS. Combined a YOLO-based detector with a custom monocular depth model, trained on open RGB-D/stereo datasets and fine-tuned on simulated space environments. Quantized the encoder–decoder depth model for Nvidia Jetson, achieving real-time deployment at 5 FPS with only a 2% accuracy drop.
  • Urban sound monitoring AI edge device (2025) — led a solar-powered audio classification device on Arm Cortex-M55/U55 for smart-city sound monitoring, over 95% accurate on user-defined events via quantization-aware training and structured pruning. In parallel, built a scalable transformer-based multi-task model (200K to several hundred million parameters) for cloud deployment, addressing training instability, vanishing/exploding gradients and long-sequence memory bottlenecks with gradient clipping, mixed-precision training and parallelized optimization.
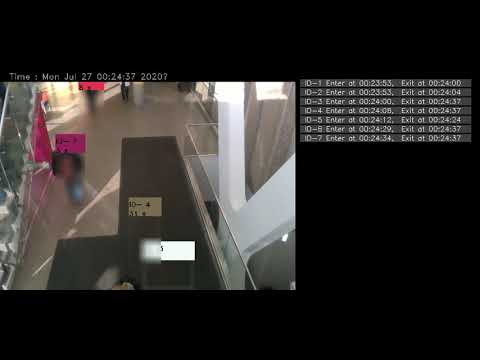
  • Smart crowd management for the City of Calgary (2018–2019) — fused a fine-tuned YOLO detector with a custom stereo-based 3D human detector for accurate counting under occlusion. Deployed across scalable edge nodes (up to 50, each handling up to 4 camera streams) running at 10 FPS, with top-down stereo placement at entrances to reduce occlusion and rigorous field validation against manual counts.
  • Satellite ship-tracking tool — combined Mask R-CNN ship detection on WorldView-3 imagery with AIS data fused via an Extended Kalman Filter, producing smooth trajectories despite noisy, irregularly-sampled AIS signals.
2015

Research Engineer

Arthur C. Clarke Institute for Modern Technologies, Colombo · May – Aug 2015

Reverse-engineered and redesigned a low-cost CCD tea colour sorter for the Sri Lankan tea industry, covering mechanical and electronic design and manufacturing oversight, for the Ministry of Technology Research and Atomic Energy.

2014 – 2015

Electronics Maintenance Engineer

S-lon Lanka (Pvt) Ltd, The Capital Maharaja Organisation, Sadalankawa, Sri Lanka · Dec 2014 – May 2015

Responsible for electrical maintenance of PVC pipe manufacturing machinery.

2013 – 2015

Electronics Design Engineer

Power Migration Partners UK Ltd, Greater Edinburgh Area (Remote) · Apr 2013 – May 2015

Delivered embedded electronics and controls solutions for the UK renewable energy and industrial automation sectors — including sensor-driven joystick control for the Skoog music instrument, embedded programming for hybrid-energy inverter controller boards, and precision microfluidic pump driver design.

2011

Trainee Engineer

Dipped Products PLC · Mar – Oct 2011

2010

Mechatronics Design Engineer

Vizu Private Ltd · Oct – Dec 2010

Projects

Urban Sound Monitoring AI Edge Device

Complex System Inc. · Mar – Jul 2025

Solar-powered Arm Cortex-M55/U55 edge device classifying user-defined urban sound events at over 95% accuracy, using quantization-aware training and structured pruning, as part of a multi-modal smart-city monitoring platform.

3D Obstacle Detection for the Canadarm2

Complex System Inc., for the Canadian Space Agency · 2024

Led a team of four building a monocular 3D obstacle-detection system for the ISS robotic arm, combining YOLO detection with a custom depth model quantized for real-time 5 FPS edge deployment on Nvidia Jetson.
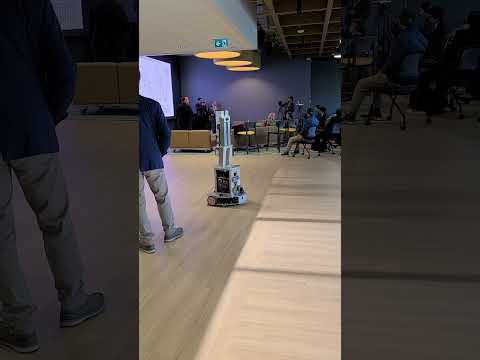
Kella receptionist robot video thumbnail

Kella — Humanoid Receptionist Robot

University of Calgary, for the City of Calgary · 2022 – 2024

Lead designer and developer of an interactive robot's full mechanical, electronic and software stack — ROS-based, with custom motion, vision and voice subsystems — built to greet and assist visitors at Calgary's municipal building.

Single Image Depth Prediction — DCViT

University of Calgary · 2021 – 2023

A Python/TensorFlow implementation of the Dual Convolution Vision Transformer, built from PhD research, for unsupervised, metric-scale depth prediction from single images.

Real-Time 3D-SLAM Software Package

University of Calgary · 2018 – 2023

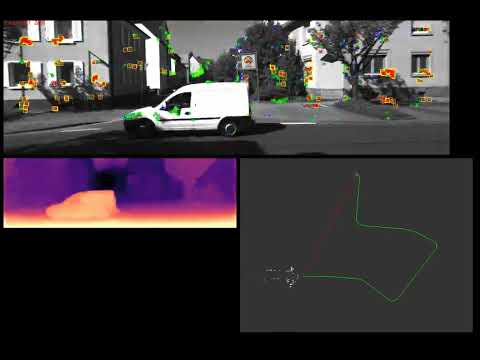
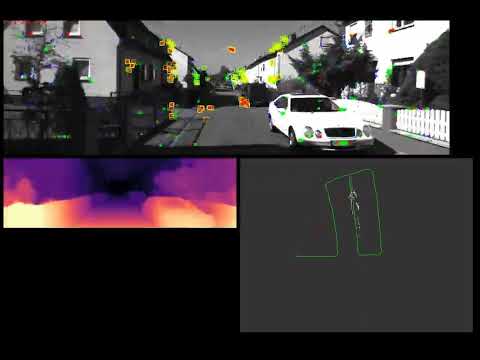
A multi-threaded C++/GTK SLAM system for Linux, with dedicated threads for depth prediction, local mapping, sparse bundle adjustment and loop closing, plus parallel keypoint matching via RANSAC and EM.
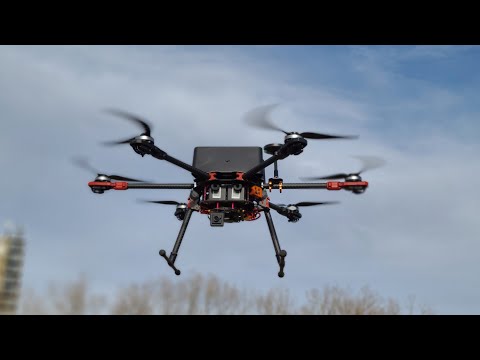
Edge-AI drone platform video thumbnail

Edge-AI Experimental Drone Platform

University of Calgary · 2021 – 2022

A hexacopter drone built from off-the-shelf components with edge-AI processing, RGB/monochrome cameras and radar, alongside a joystick-controlled GUI for lab experiments.

Custom wide-baseline multi-camera vehicle roof rig setup
Monochrome global shutter camera frame sample 1
Monochrome global shutter camera frame sample 4
High-resolution color camera mid-rig dataset frame sample

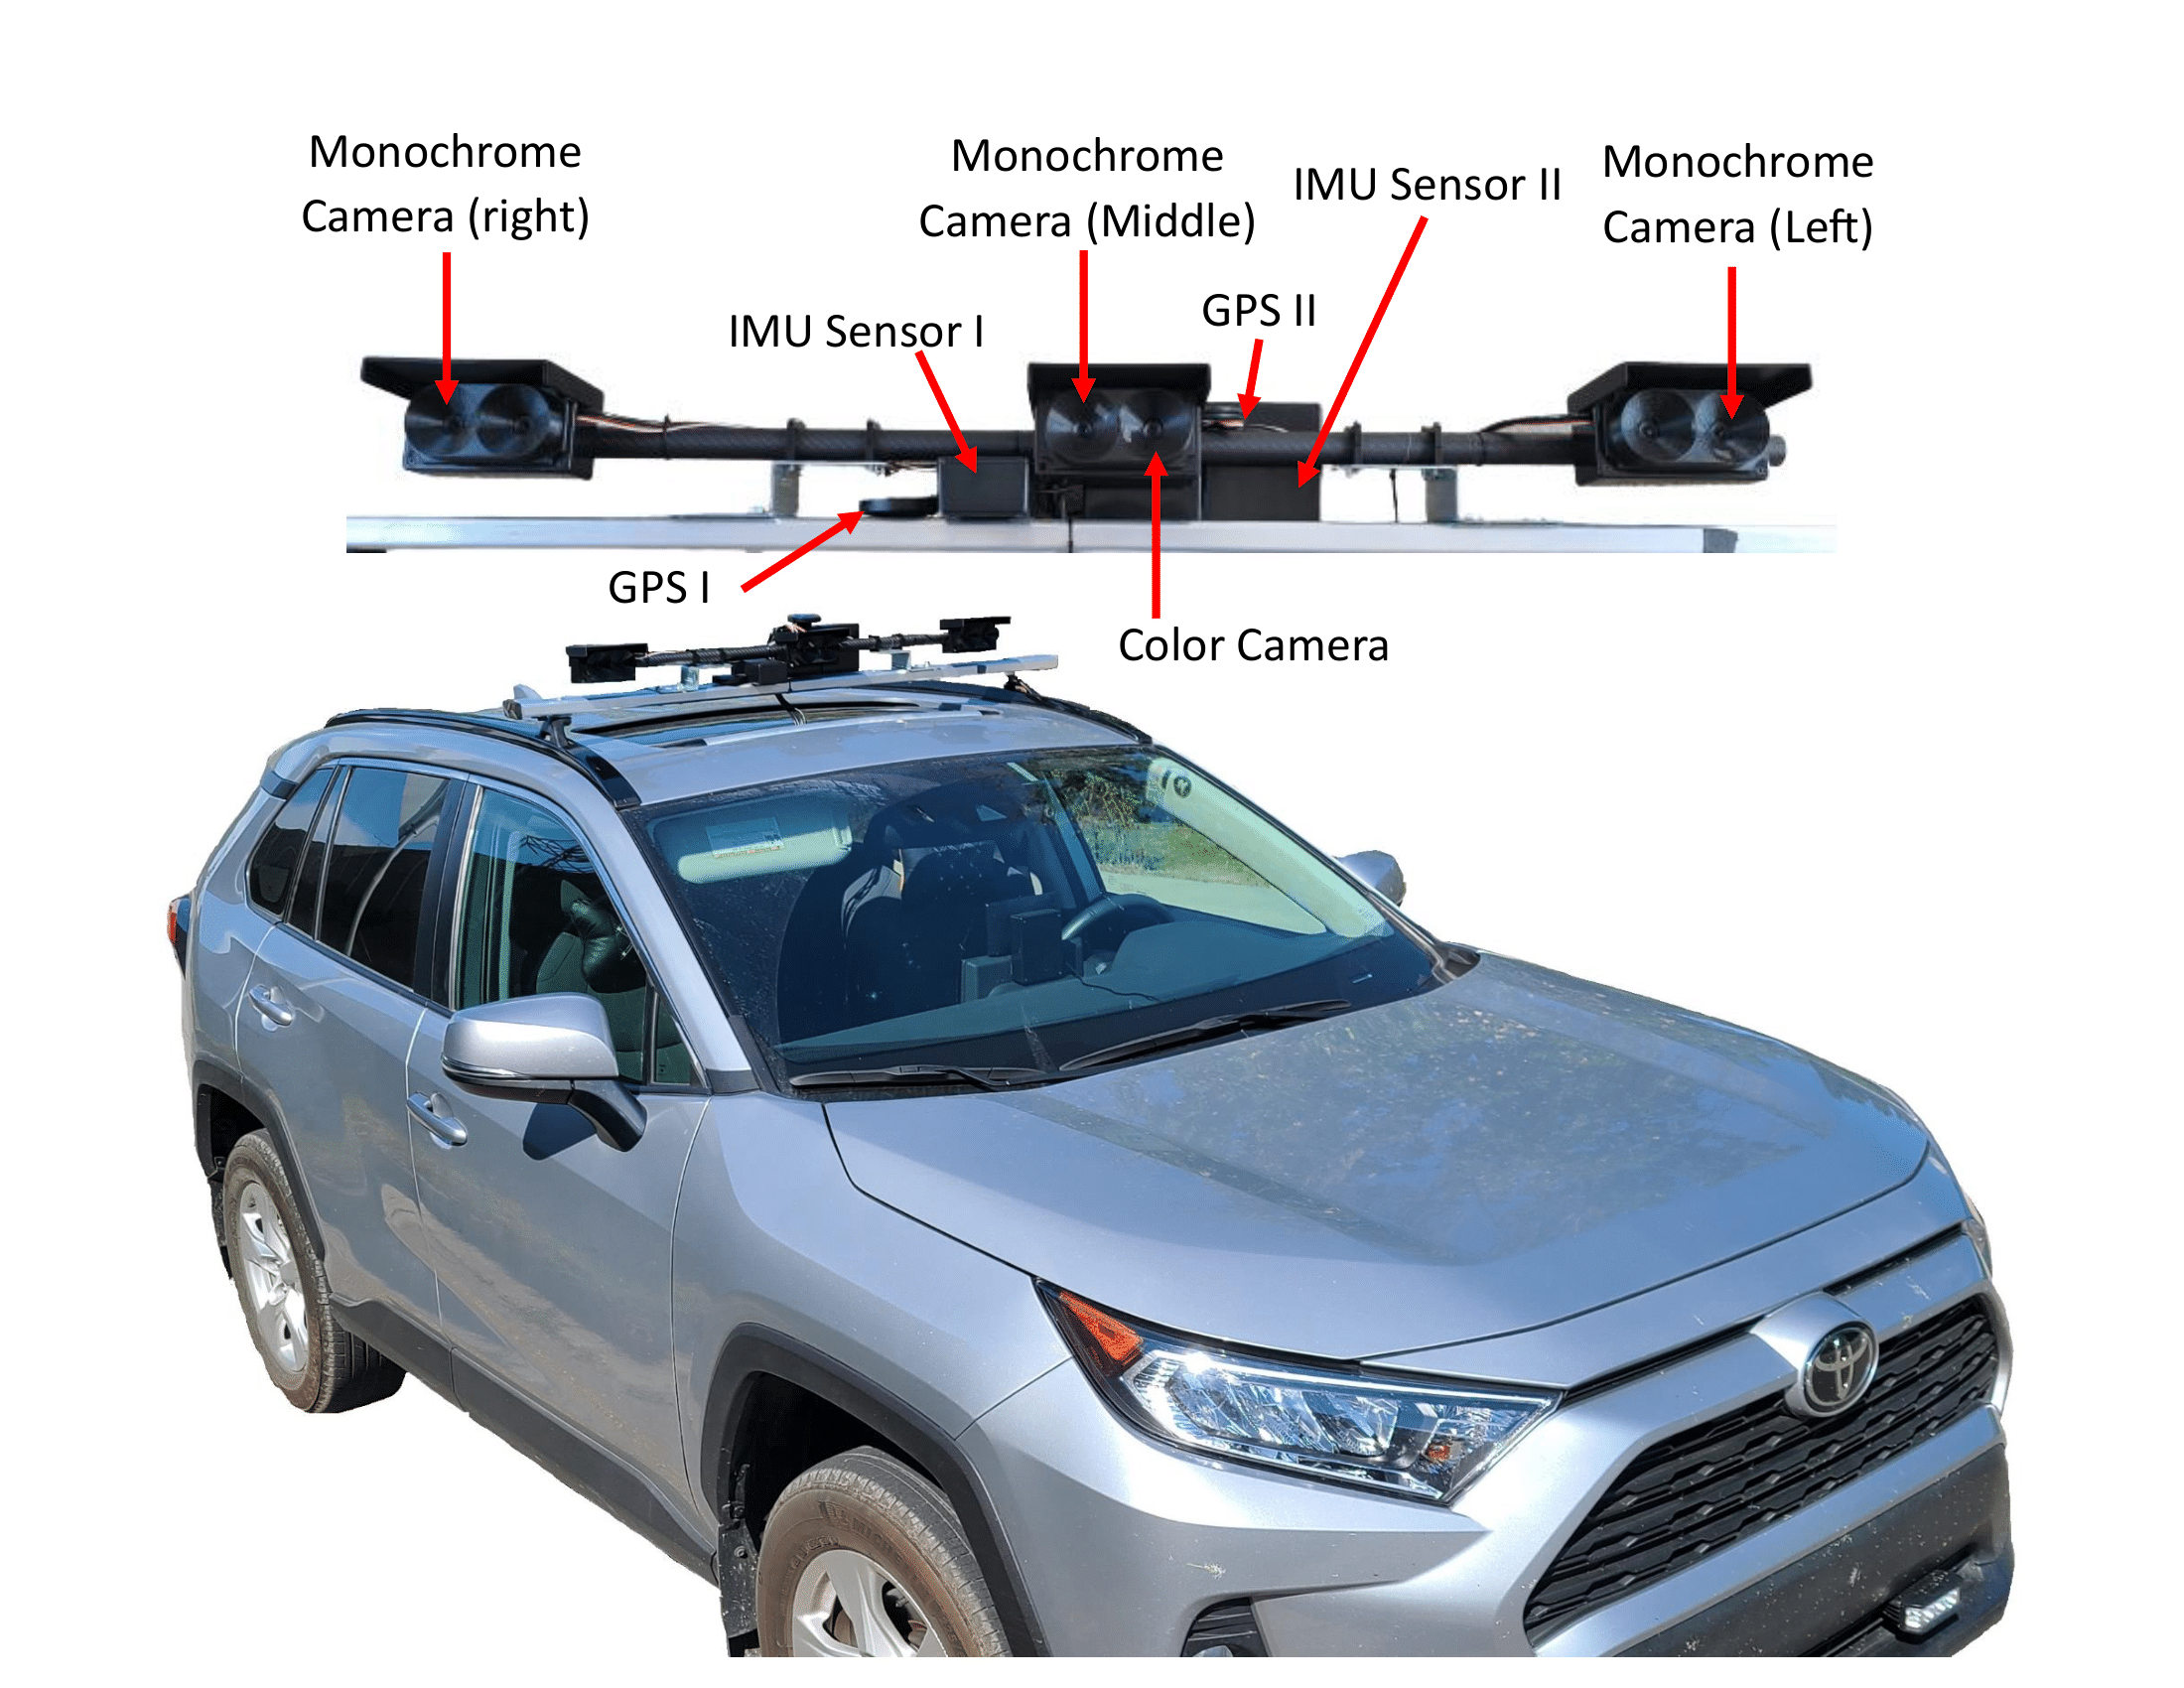
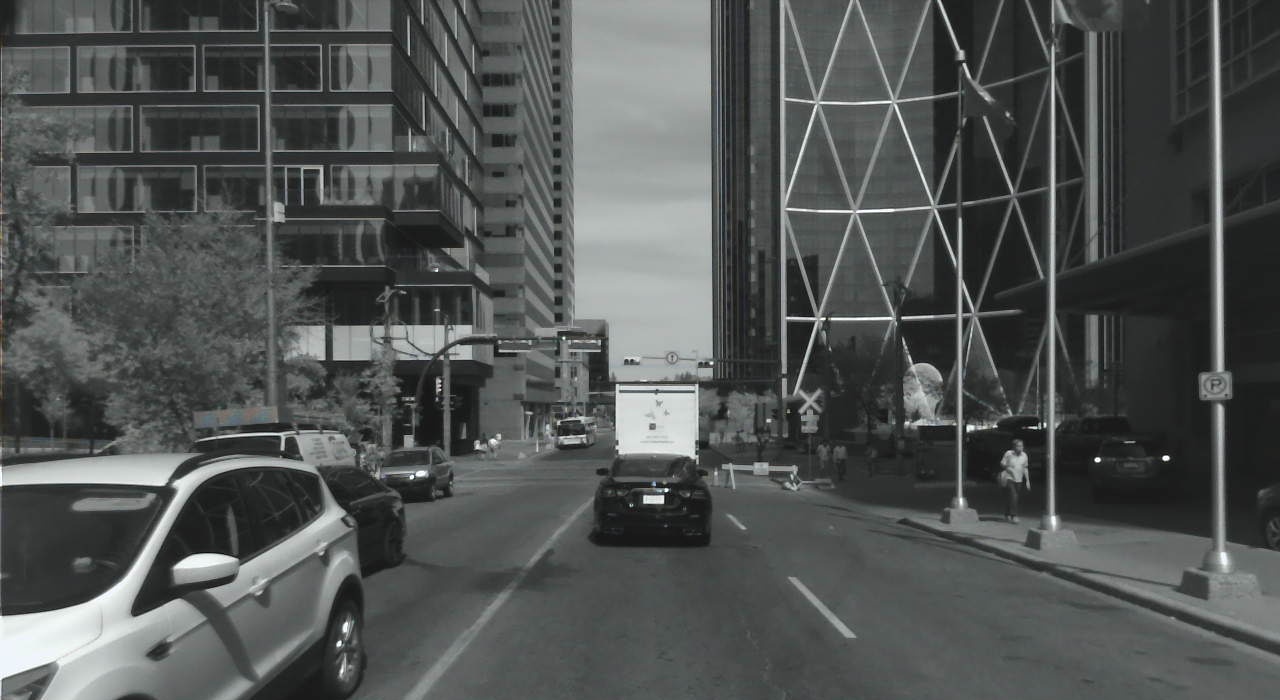
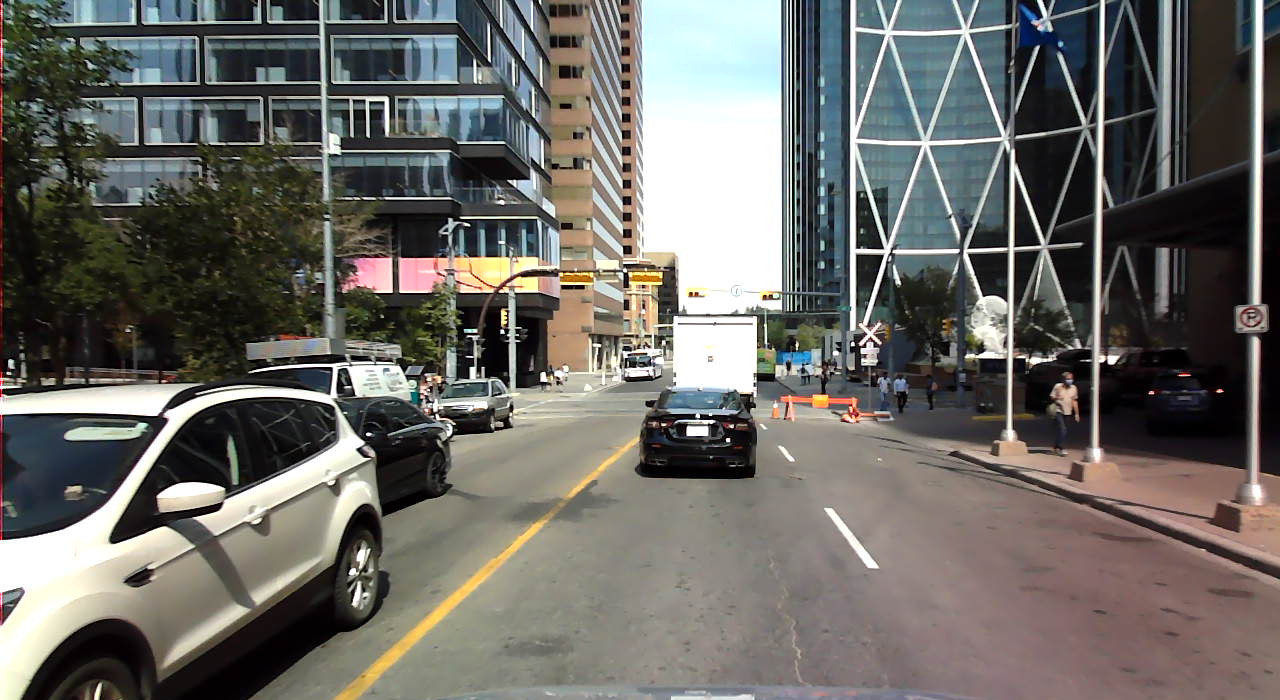
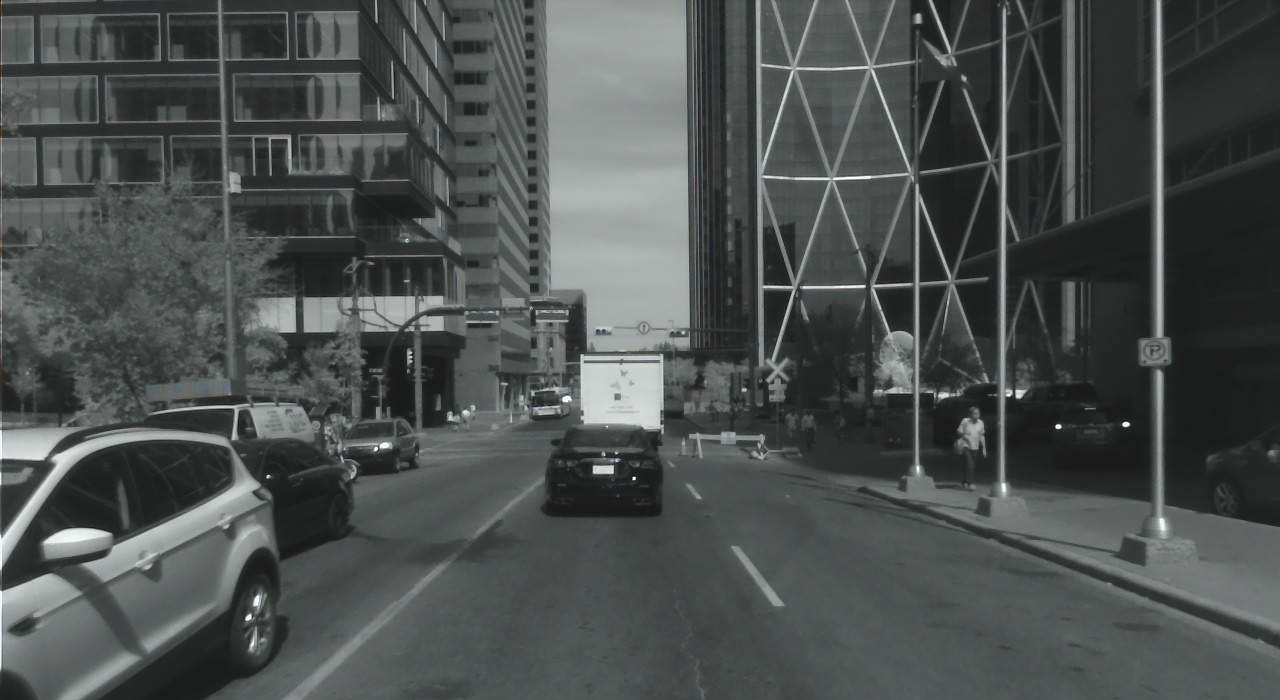
Stereo Autonomous Driving Dataset

University of Calgary · 2020 – 2021

A custom wide-baseline stereo rig — three monochrome global-shutter cameras plus one high-resolution colour camera — with IMU/GPS ground truth, collected across Calgary terrain for SLAM and depth research.

Smart Crowd Management for Urban Environments

City of Calgary · 2018 – 2019

Multi-view RGB and RGB-D crowd analytics, fusing a fine-tuned YOLO detector with a custom stereo-based 3D human detector, scaled to 50 edge nodes running at 10 FPS for real-time people counting and service-time tracking.

Outdoor 3D Reconstruction

2016 – 2017

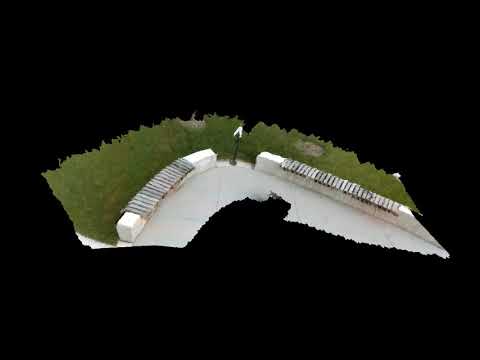
Enhanced outdoor spatial mapping using Intel RealSense depth cameras. Improved localization and 3D reconstruction accuracy by fusing dense point clouds into a pose graph optimization pipeline for robust environment modeling.
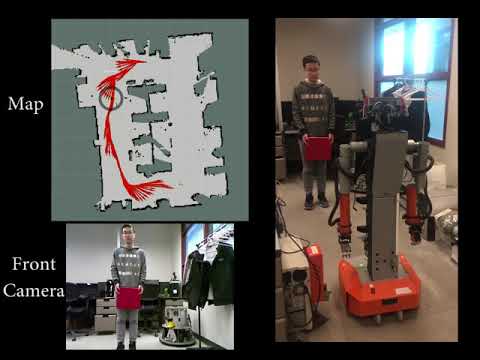
Robot autonomous navigation video thumbnail

Robot Autonomous Navigation

Schulich School of Engineering, University of Calgary · 2015 – 2017

Ported a robot's software from Windows to ROS-Kinetic, then built control software for sensor fusion, target detection, path planning and trajectory navigation, integrating a laser scanner and RGB-D camera.

Earlier engineering projects

Reverse Engineering of a CCD Tea Colour Sorter

Arthur C. Clarke Institute for Modern Technologies · 2015

Led mechanical and electronic design of a low-cost CCD-based tea colour sorter for the Sri Lankan tea industry, including manufacturing oversight.

Super-Heated Extraction System

University of Moratuwa · 2014

Reverse-engineered and redesigned an HPLC pump for super-heated extraction research at the Faculty of Applied Science, University of Kelaniya.
Two-wheel self-balancing robot video thumbnail

Two-Wheel Self-Balancing Robot

University of Moratuwa · 2011

Mechanical, electronics and control-system design for a self-balancing robot, using sensor fusion of gyroscope and accelerometer data for real-time stability.
Line-tracing mobile robot video thumbnail

Two-Wheel Line-Tracing Mobile Robot

University of Moratuwa · 2011

Competition robot built with a two-person team to autonomously detect and transport bricks to a goal location, covering mechanical, sensor and control design.
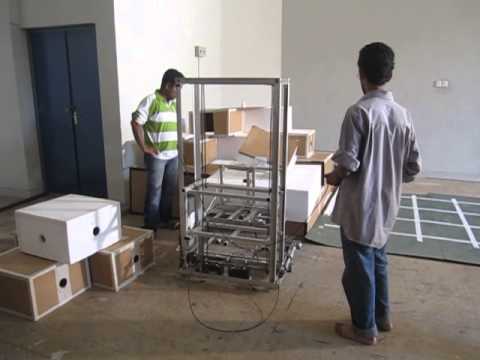
Robocon 2010 video thumbnail

Robocon 2010

ABU Robocon, Cairo · 2010

One of three representing Sri Lanka; led mechanical design, fabrication and system integration of two fully/semi-automated pyramid-building robots.

Skoog Music Instrument R&D

Power Migration Partners UK Ltd · 2014

Analyzed magnetic-sensor joystick output patterns and built a multivariate Gaussian model to estimate pressure-point location for the Skoog music instrument.

Hybrid-Energy Inverter Controller Board

Power Migration Partners UK Ltd · 2013

Embedded programming and I/O calibration on the F28M35M52C microcontroller for a hybrid-energy inverter controller board, with extensive state-space testing.

Microfluidic Pump Driver Improvement

Power Migration Partners UK Ltd · 2013

Re-engineered a sinusoidal-drive microfluidic pump circuit, adding constant-current control and a redesigned PCB layout for stability and reduced interference.

Wireless Display System for Performance Measurement

MAS Holdings Casualine Factory · 2013

Designed a wireless RF production-line monitoring system, tracking per-operator task times across hundreds of input nodes for a master display.

Wireless Data Monitoring System

Melwa · 2012

Built a code-based RF communication system for a steel and concrete wire plant, enabling reliable status updates in a high dust/noise manufacturing environment.
The full project archive is on GitHub and YouTube.

Skills

Programming

15+ years across C, C++ and Python, plus microcontroller programming. Proficient in OpenCV, OpenGL and GTK for real-time, sensor-driven software pipelines.

Software & frameworks

ROS, PyTorch, TensorFlow, Keras Functional API, ONNX, TensorRT, MATLAB.

Deep learning

CNNs, Vision Transformers, supervised and unsupervised learning, object detection and tracking, model quantization and pruning, multi-task learning, large-model distillation.

Acceleration & deployment

Custom CUDA development, GPU-accelerated recursive probabilistic estimators, TensorRT/ONNX deployment, quantization-aware training, structured pruning.

Areas of expertise

Estimation theory, SLAM and 3D perception (sensor-based and deep learning-based generative 3D), monocular and stereo vision, multi-view geometry, optical flow and image registration.

Hardware

3D CAD, circuit and PCB design, sensors, actuators and microcontrollers, low-level real-time software.

Awards

  • 2024 PhD thesis nominated for the Governor General's Gold Medal and Chancellor's Graduate Medal, University of Calgary
  • 2020 Research Productivity Award, Electrical & Computer Engineering, University of Calgary
  • 2019 Alberta Graduate Excellence Scholarship (AGES)
  • 2018 Research Productivity Award, Electrical & Computer Engineering, University of Calgary
  • 2017 Academic Excellence Award, Electrical & Computer Engineering, University of Calgary
  • 2017 Alberta National Award Scholarship
  • 2014 Dean's List, Faculty of Engineering, University of Moratuwa
  • 2010 ABU Robocon — represented Sri Lanka at the Asian Pacific International Robot Contest

Publications

The list of papers is on Google Scholar.

View on Google Scholar

Contact

Email

gayansampathefac@gmail.com

Feel free to reach out for collaborations, roles, or questions about any of the projects above.